
2.5D и 3D видеоизмерения: возможности оси Z и границы выбора
2.5D добавляет ось Z через фокусировку или лазер; истинное 3D требует контактных датчиков или интерферометрии.
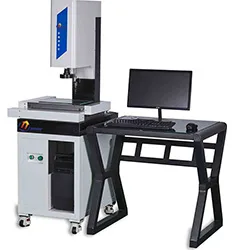
Where 2.5D gets its Z
A conventional vision machine is intrinsically two-dimensional: X/Y come from linear scales, and Z only drives focusing. The so-called 2.5D Z measurement follows two paths: focus-based, searching the contrast evaluation function for the sharpest position with repeatability of about 1 to 3 μm, suitable for transparent parts and step heights; or an optional laser triangulation or chromatic confocal head reaching ±(2-5) μm over a 10 to 30 mm range. 2.5D fits planar parts with a few height features, such as PCBs, stampings and phone structural parts.
Three routes to true 3D
| Route | Accuracy | Throughput | Best for |
|---|---|---|---|
| Vision plus tactile probe (multisensor) | ±(3+L/200) μm | Medium | Hole depth, side walls, occluded features |
| Structured light / line laser scanning | ±(10-30) μm | High | Freeform surfaces, reverse engineering |
| White-light interferometry / confocal | 0.01-0.1 μm | Low | Surface texture, microstructures |
Selection criteria
Look at the spatial distribution of features: coplanar features with a few steps are fine for 2.5D; side holes, deep slots and 3D surfaces demand true 3D. Then accuracy: within 5 μm in Z, a multisensor machine is the only economical choice; sub-micron needs push you to white-light interferometry, which trades tiny fields of view and no large-part capability. Material matters too: lasers dislike mirror surfaces, transparent parts suit confocal heads, soft materials need non-contact.
Multisensor coordination
The key to a vision-plus-tactile machine is unifying the two coordinate systems: calibrate the offset between the optical center and the probe ball center with a reference sphere, typically tens of microns, and after calibration both sensors should agree within ±5 μm on the same feature. Programs can then mix calls — optics for the outer profile, probe for hole depth — finishing full dimensional inspection in one setup, which is exactly the core value of multisensor machines.


