 HOT
 YR25D10 · 2026-11-17 · +86 21 5748 2007
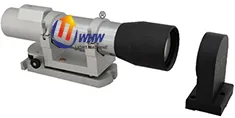
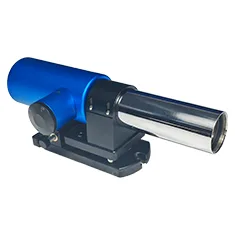
YR25D10 Photoelectric Autocollimator (25 m,1.0arcsec)
Photoelectric Autocollimator · 25 m,1.0arcsec
型番YR25D10
- 物镜焦距240mm
- 物镜口径60mm(NA.=90%)
- 光源类型大功率半导体光源(中心波长λ=630nm)
- 探测器高分辨率图像传感器
By submitting you agree to our privacy policy.
01
製品概要
YR25D10大口径电子自准直仪技术参数:
物镜焦距:240mm;
物镜口径:60mm(NA.=90%);
光源类型:大功率半导体光源(中心波长λ=630nm);
探测器:高分辨率图像传感器;
目镜:软件显示的电子目镜;
测量频响:7.5Hz TYP.;
接口:USB2.0高速接口;
测量距离:25m;
最大读数视场:1600*1600(角秒);
分辨率:0.1角秒;
精度:1(角秒);
外形尺寸:305(L)*80(W)*115(H)mm;
重量:2.4kg;
四、YR25D10大口径电子自准直仪选配附件:
1.带磁反射镜(特殊定货)
2.光学直角器(特殊定货)
3.激光找准器(特殊定货)
4、专用升降平台(特殊定货)
5、专用三角架(特殊定货)
五、自准直仪的典型应用:
1.直线度测试:直线度测量和验证是自准直仪在机械制造行业典型的应用之一。本系列准直仪测试直线度具有精度高、重复性好和双方向同时检测的优点。在直线度测量中,借助一个桥板将角度量转化为位移量进行测量,测量中使用首尾搭接法通过在整个测量行程内分段移动桥板完成测量过程。如图:
2.自准直仪平面度测试:平面度测量和验证是自准直仪进行直线度测量的拓展应用。通过对待测平面的若干直线进行测量(通常测量为米字型或者网格分布),最后将测试结果进行计算分析。整个测量过程根据精度的要求和平面尺寸选用2个或3个不同尺寸的测量桥板进行配合使用。如图:
3.自准直仪垂直度测试:垂直度测量和验证原理为采用自准直仪分别测量两条待测导轨的直线度后,根据测量结果分析出两条导轨的共面垂直度偏差,测量中基准的传递采用直角转像镜(光学五棱镜)进行。如图,先测试一条导轨的直线度并作为基准线,然后将直角转像镜放置在另一导轨位置后进行第二条直线测量并作为测量线。使用基准线的直线度包容区旋转90度后对测量线的直线度曲线进行包容后的结果即为垂直度偏差值。
4.自准直仪平行度测试:平行度测量和验证的基本原理是采用自准直仪分别测量两条待测导轨的直线度后,根据测量结果计算出两条导轨的共面平行度偏差,测量中的基准传递是采用直角转像镜(光学五棱镜)进行。如图,首先测量一条导轨的直线度并作为基准线,随后将直角转像镜移动至另一导轨位置后进行第二条直线测量并作为测量线。使用基准线的直线度包容区平移后对测量线的直线度曲线进行包容后的结果即为平行度偏差值。
5.自准直仪位置不确定度测试:自准直仪结合多面棱体和检测的旋转平台可以进行角度的不确定度检测。
6.多个自准直仪组合对光学块进行比较测量。(可以组合成测角仪)
YR25D10 Photoelectric Autocollimator (25 m,1.0arcsec) supplied by CHWES. 13 key specifications available on request.
02
仕様
| 物镜焦距 | 240mm |
|---|---|
| 物镜口径 | 60mm(NA.=90%) |
| 光源类型 | 大功率半导体光源(中心波长λ=630nm) |
| 探测器 | 高分辨率图像传感器 |
| 目镜 | 软件显示的电子目镜 |
| 测量频响 | 7.5Hz TYP. |
| 接口 | USB2.0高速接口 |
| 测量距离 | 25m |
| 最大读数视场 | 1600*1600(角秒) |
| 分辨率 | 0.1角秒 |
| 精度 | 1(角秒) |
| 外形尺寸 | 305(L)*80(W)*115(H)mm |
| 重量 | 2.4kg |
* Generated by rule engine over the product database; for pre-selection only.
03
測定原理
An autocollimator projects an illuminated cross-line as a parallel beam onto an external mirror. The mirror returns the beam, which re-images on the reticle or a CCD/CMOS sensor. If the mirror tilts by θ, the return image shifts by s = 2f·tanθ — the angle is doubled optically and magnified by the focal length.
Photoelectric readout (CCD/CMOS centroiding or PSD differential detection with software subdivision) reaches 0.1″ resolution. Dual-axis models read horizontal and vertical tilt simultaneously; large-field versions such as the HXDS15-4000 (4000×3000″) image a wide angular range for dynamic measurements.
Stepping a mirror bridge along a guideway converts per-step tilts θi into elevation differences hi = L·tanθi for straightness and flatness; with polygons or multi-tooth tables the same instrument calibrates circular indexing.
04
Process animation
- Setup: mount the mirror on a bridge of span L at the start of the guideway.
- Zeroing: adjust the autocollimator until the cross image centres, record the initial reading.
- Step: advance the bridge by L each station, logging θi (both axes on dual-axis models).
- Evaluate: accumulate hi = L·tanθi and rate straightness or flatness by end-point or minimum-zone methods.
- Indexing: with a polygon, successive face readings give the index error; issue the report.
05
Calculation & formulas
1. Angle-image relation: θ = s/(2f); with f = 500 mm and s = 5 µm, θ ≈ 1.03″ (1″ ≈ 4.85 µrad).
2. Resolution: 0.1″ corresponds to s ≈ 0.485 µm at f = 500 mm — pixels ≤5 µm plus 1/10 subdivision.
3. Elevation step: h = L·tanθ; a 100 mm bridge at 2″ gives h ≈ 0.97 µm.
4. End-point straightness: cumulative deviations Δi = Σhk − (i/n)Σh, error f = max(Δ) − min(Δ); the minimum-zone method rotates the datum per convex/concave/alternating criteria.
5. Indexing: per-face errors φj minus nominal; the closure Σφ = 0 checks the full circle.
06
規格
| Standard | Title | Scope |
|---|---|---|
| JJG 202-2007 | Verification regulation of autocollimators | Indication error and resolution |
| GB/T 11336-2004 | Detection of straightness error | Guideway and surface-plate straightness |
| GB/T 1958-2017 | GPS — detection and evaluation of geometrical deviations | Flatness, squareness and other form errors |
| ISO 230-1 | Machine tools — geometric accuracy tests | Machine acceptance |
| JJG 283-2007 | Multi-tooth indexing table verification | Circular indexing calibration |
Accredited labs must also hold 20±0.5 °C and vibration isolation, with instrument error within the 0.5″/1″ class.
07
選定ガイド
1. Resolution decides acceptance capability: 0.1″ (HXJL300-0.1, HXJL300U-0.1, HXJL300UH-0.1) for precision machines, rotary tables and laboratory standards; 0.2–0.3″ for general machine acceptance; 0.5–1″ (HXM series) for on-site alignment and long-range monitoring.
2. Distance decides aperture: 5–10 m with HXM2010/HXJL200; 20–30 m with HXM2020/HXM3030; 35–40 m with HXM3540; 50 m baseline with HXM4050M-1. Mirror aperture and light budget matter more as distance grows.
3. Single or dual axis: single-axis HXJL for one-direction straightness; dual-axis HXM for both directions and polygon indexing.
4. Dynamic work: HXDS15-4000 with a large field and high sampling rate for rotary-table oscillation, shaker tables and thermal drift.
5. Accessories: mirror bridges at 50/100/200 mm span, 12/24/36-face polygons, pentaprism for squareness, intermediate targets for long runs, thermal hoods for workshops.
6. Software and compliance: end-point, minimum-zone and least-squares evaluation with ISO 230-1 reports; labs also need the standard-artefact interface for verification.
| Model | Resolution | Distance | Typical use |
|---|---|---|---|
| HXJL300UH-0.1 | 0.1″ | 0–10 m | Precision tables, lab standards |
| HXJL300U-0.1 / HXJL300-0.1 | 0.1″ | 0–10 m | Precision guideways and plates |
| HXJL300-0.2 / -0.3 | 0.2–0.3″ | 0–10 m | General machine acceptance |
| HXM2010 / HXM2020 | 0.5–1″ | 10–20 m | Mid-size gantry, moulding machines |
| HXM3030 / HXM3540 | 0.5–1″ | 30–40 m | Large gantry, marine parts |
| HXM4050M-1 | 1″ | 50 m | Long guideways, cross-shop datums |
| HXDS15-4000 | Dynamic dual-axis | Large field | Table oscillation, vibration |
Common mistakes: using a 1″ unit to trend a 0.02 mm/m guideway; ignoring bridge sag under mirror weight; not controlling air currents and floor vibration, so readings never settle.
08
試験方法
Environment: 20±0.5 °C (±2 °C on the floor with compensation), shield air currents and sunlight; soak the instrument and bridge for 30 minutes on an isolated base.
Straightness procedure: ① clean the guideway and set the bridge span L; ② zero at the first station after 10 minutes of warm-up; ③ step by exactly L (within 0.5 mm), logging both axes; ④ evaluate by end-point and minimum-zone methods and report the larger; ⑤ record span, temperature and uncertainty (typically U ≈ 0.5″ + 2% of reading).
Intermediate checks: monthly 12-face polygon closure (Σ = 0, residual ≤0.3″); send standards out every two years.
Pitfalls: span errors feed straight into height differences; air currents jitter the centroid; thermal gradients bend long guideways optically — measure morning and afternoon and average.
09
Industry applications
- Machine tools: gantry and boring-mill guideway straightness, column and spindle squareness, table flatness to ISO 230-1 and GB/T 11336; repeatability ≤1 µm over 24 m with the end-point method.
- Metrology institutes: surface-plate flatness, cross-checks with electronic levels, small-angle standard build-up; indication error within ±0.5″/±1″ per JJG 202-2007.
- Indexing and rotary tables: multi-tooth tables, optical and CNC rotary tables, RV reducer backlash; full-circle checks with 12/24/36-face polygons, indexing error ≤±1″.
- Semiconductor stages: micro-angle feedback and thermal drift monitoring on air-bearing and wafer stages, resolution ≤0.01″ at ≥10 Hz.
- Inertial navigation and optics: reference-mirror alignment and angle transfer for gyro platforms, theodolites and interferometers.
- Energy equipment: turbine bearing alignment, wind-turbine flange squareness, long hydro shaft lines.
- Rail and elevators: guide-rail straightness and twist, body datum flatness, often at 30–50 m working distance.
- Research and teaching: optical bench levelling and micro-angle measurement.
10
Price and lead time for this model
同シリーズ
すべて見る→Photoelectric Autocollimators
HOT HOT
 HOT
MC030-MAT200/38/1 Photoelectric Autocollimator (10 m1″)
Photoelectric Autocollimator · 10 m1″
- 型号MC030-MAT200/38/1
- 物镜焦距200mm